以太网驱动的流程浅析(三)-ifconfig的-19错误最底层分析
我们继续沿着上一篇的以太网思路来继续分析,目的是为了学习以太网这块从应用层到底层的整块加载和匹配流程。
【硬件环境】 Imx6ul
【Linux kernel版本】 Linux4.1.15
【以太网phy】 Realtek8201f
1. 以太网流程分析跟踪
1.1 ifconfig的-19错误最底层分析
首先我们来看nxp的以太网驱动代码
路径:drivers/net/ethernet/freescale
static int

fec_enet_open(struct net_device *ndev)

{

	struct fec_enet_private *fep = netdev_priv(ndev);

	const struct platform_device_id *id_entry =

				platform_get_device_id(fep->pdev);

	int ret;


	pinctrl_pm_select_default_state(&fep->pdev->dev);

	ret = fec_enet_clk_enable(ndev, true);

	if (ret)

		return ret;


	/* I should reset the ring buffers here, but I don't yet know

	 * a simple way to do that.

	 */


	ret = fec_enet_alloc_buffers(ndev);

	if (ret)

		goto err_enet_alloc;


	/* Init MAC prior to mii bus probe */

	fec_restart(ndev);


	/* Probe and connect to PHY when open the interface */

	ret = fec_enet_mii_probe(ndev);

	if (ret)

		goto err_enet_mii_probe;


	napi_enable(&fep->napi);

	phy_start(fep->phy_dev);

	netif_tx_start_all_queues(ndev);


	pm_runtime_get_sync(ndev->dev.parent);

	if ((id_entry->driver_data & FEC_QUIRK_BUG_WAITMODE) &&

	    !fec_enet_irq_workaround(fep))

		pm_qos_add_request(&fep->pm_qos_req,

				   PM_QOS_CPU_DMA_LATENCY,

				   0);

	else

		pm_qos_add_request(&fep->pm_qos_req,

				   PM_QOS_CPU_DMA_LATENCY,

				   PM_QOS_DEFAULT_VALUE);


	device_set_wakeup_enable(&ndev->dev, fep->wol_flag &

				 FEC_WOL_FLAG_ENABLE);

	fep->miibus_up_failed = false;


	return 0;


err_enet_mii_probe:

	fec_enet_free_buffers(ndev);

err_enet_alloc:

	fep->miibus_up_failed = true;

	if (!fep->mii_bus_share)

		pinctrl_pm_select_sleep_state(&fep->pdev->dev);

	return ret;

}
看了后我们可以通过打印信息知道是fec_enet_mii_probe函数返回的-19,继续跟踪进去:
static int fec_enet_mii_probe(struct net_device *ndev)

{

	struct fec_enet_private *fep = netdev_priv(ndev);

	struct phy_device *phy_dev = NULL;

	char mdio_bus_id[MII_BUS_ID_SIZE];

	char phy_name[MII_BUS_ID_SIZE + 3];

	int phy_id;

	int dev_id = fep->dev_id;


	fep->phy_dev = NULL;


	if (fep->phy_node) {

		phy_dev = of_phy_connect(ndev, fep->phy_node,

					 &fec_enet_adjust_link, 0,

					 fep->phy_interface);

		if (!phy_dev)

			return -ENODEV;

	} else {

		/* check for attached phy */

		for (phy_id = 0; (phy_id < PHY_MAX_ADDR); phy_id++) {

			if ((fep->mii_bus->phy_mask & (1 << phy_id)))

				continue;

			if (fep->mii_bus->phy_map[phy_id] == NULL)

				continue;

			if (fep->mii_bus->phy_map[phy_id]->phy_id == 0)

				continue;

			if (dev_id--)

				continue;

			strlcpy(mdio_bus_id, fep->mii_bus->id, MII_BUS_ID_SIZE);

			break;

		}


		if (phy_id >= PHY_MAX_ADDR) {

			netdev_info(ndev, "no PHY, assuming direct connection to switch\n");

			strlcpy(mdio_bus_id, "fixed-0", MII_BUS_ID_SIZE);

			phy_id = 0;

		}


		snprintf(phy_name, sizeof(phy_name),

			 PHY_ID_FMT, mdio_bus_id, phy_id);

		phy_dev = phy_connect(ndev, phy_name, &fec_enet_adjust_link,

				      fep->phy_interface);

	}


	if (IS_ERR(phy_dev)) {

		netdev_err(ndev, "could not attach to PHY\n");

		return PTR_ERR(phy_dev);

	}


	/* mask with MAC supported features */

	if (fep->quirks & FEC_QUIRK_HAS_GBIT) {

		phy_dev->supported &= PHY_GBIT_FEATURES;

		phy_dev->supported &= ~SUPPORTED_1000baseT_Half;

#if !defined(CONFIG_M5272)

		phy_dev->supported |= SUPPORTED_Pause;

#endif

	}

	else

		phy_dev->supported &= PHY_BASIC_FEATURES;


	phy_dev->advertising = phy_dev->supported;


	fep->phy_dev = phy_dev;

	fep->link = 0;

	fep->full_duplex = 0;


	netdev_info(ndev, "Freescale FEC PHY driver [%s] (mii_bus:phy_addr=%s, irq=%d)\n",

		    fep->phy_dev->drv->name, dev_name(&fep->phy_dev->dev),

		    fep->phy_dev->irq);


	return 0;

}
#define EXDEV 18 /* Cross-device link */
#define ENODEV 19 /* No such device */
#define ENOTDIR 20 /* Not a directory */ if (!phy_dev)
return -ENODEV;哈哈,看到这里答案出来了,-19就是这里返回的,也就是说phy_dev是NULL
那为什么呢?我们跟进去看下,of_phy_connect,功能注释已经写的很清楚了
Connect to the phy described in the device tree,从设备树上获取phy的相关描述信息,路径:drivers/of/of_mdio.c
/**

 * of_phy_connect - Connect to the phy described in the device tree

 * @dev: pointer to net_device claiming the phy

 * @phy_np: Pointer to device tree node for the PHY

 * @hndlr: Link state callback for the network device

 * @iface: PHY data interface type

 *

 * Returns a pointer to the phy_device if successful.  NULL otherwise

 */

struct phy_device *of_phy_connect(struct net_device *dev,

				  struct device_node *phy_np,

				  void (*hndlr)(struct net_device *), u32 flags,

				  phy_interface_t iface)

{

	struct phy_device *phy = of_phy_find_device(phy_np);


	if (!phy)

		return NULL;


	phy->dev_flags = flags;


	return phy_connect_direct(dev, phy, hndlr, iface) ? NULL : phy;

}

EXPORT_SYMBOL(of_phy_connect);
既然phy_device是空的,也就是说struct phy_device *phy = of_phy_find_device(phy_np);
没有从这里面拿到phy_device
/**

 * of_phy_find_device - Give a PHY node, find the phy_device

 * @phy_np: Pointer to the phy's device tree node

 *

 * Returns a pointer to the phy_device.

 */

struct phy_device *of_phy_find_device(struct device_node *phy_np)

{

	struct device *d;

	if (!phy_np)

		return NULL;


	d = bus_find_device(&mdio_bus_type, NULL, phy_np, of_phy_match);

	return d ? to_phy_device(d) : NULL;

}

EXPORT_SYMBOL(of_phy_find_device);
看下如下两个函数
/**

 * bus_find_device - device iterator for locating a particular device.

 * @bus: bus type

 * @start: Device to begin with

 * @data: Data to pass to match function

 * @match: Callback function to check device

 *

 * This is similar to the bus_for_each_dev() function above, but it

 * returns a reference to a device that is 'found' for later use, as

 * determined by the @match callback.

 *

 * The callback should return 0 if the device doesn't match and non-zero

 * if it does.  If the callback returns non-zero, this function will

 * return to the caller and not iterate over any more devices.

 */

struct device *bus_find_device(struct bus_type *bus,

			       struct device *start, void *data,

			       int (*match)(struct device *dev, void *data))

{

	struct klist_iter i;

	struct device *dev;


	if (!bus || !bus->p)

		return NULL;


	klist_iter_init_node(&bus->p->klist_devices, &i,

			     (start ? &start->p->knode_bus : NULL));

	while ((dev = next_device(&i)))

		if (match(dev, data) && get_device(dev))

			break;

	klist_iter_exit(&i);

	return dev;

}

EXPORT_SYMBOL_GPL(bus_find_device);
/* Helper function for of_phy_find_device */
static int of_phy_match(struct device *dev, void *phy_np)
{
return dev->of_node == phy_np;
}这里我需要解释下了,bus_find_device(&mdio_bus_type, NULL, phy_np, of_phy_match);
从bus总线上找到device,也就是我们的phy_device,
return d ? to_phy_device(d) : NULL;#define to_phy_device(d) container_of(d, struct phy_device, dev)如果找到就返回phy_device,否则就返回NULL
这个bus是指mdio_bus_type,如下:
d = bus_find_device(&mdio_bus_type, NULL, phy_np, of_phy_match);struct bus_type mdio_bus_type = {
.name = "mdio_bus",
.match = mdio_bus_match,
.pm = MDIO_BUS_PM_OPS,
.dev_groups = mdio_dev_groups,
};
EXPORT_SYMBOL(mdio_bus_type);1.2 以太网硬件知识
那mdio又是什么呢?这就是以太网的知识了,我们看下以太网的硬件接法:
=================================================================
如下内容转自:https://blog.csdn.net/fun_tion/article/details/70270632
1.概述
MII即“媒体独立接口”,也叫“独立于介质的接口”。它是IEEE-802.3定义的以太网行业标准。它包括一个数据接口,以及一个MAC和PHY之间的管理接口。RMII全称为“简化的媒体独立接口”,是IEEE-802.3u标准中除MII接口之外的另一种实现。(此处内容来源于网络)
2.独立于介质的接口(MII)
独立于介质的接口(MII)用于MAC与外接的PHY互联,支持10Mbit/s和100Mbit/s数据传输模式。MII的信号线如下图所示:

MII_TX_CLK:发送数据使用的时钟信号,对于10M位/s的数据传输,此时钟为2.5MHz,对于100M位/s的数据传输,此时钟为25MHz。
MII_RX_CLK:接收数据使用的时钟信号,对于10M位/s的数据传输,此时钟为2.5MHz,对于100M位/s的数据传输,此时钟为25MHz。
MII_TX_EN:传输使能信号,此信号必需与数据前导符的起始位同步出现,并在传输完毕前一直保持。
MII_TXD[3:0]:发送数据线,每次传输4位数据,数据在MII_TX_EN信号有效时有效。MII_TXD[0]是数据的最低位,MII_TXD[3]是最高位。当MII_TX_EN信号无效时,PHY忽略传输的数据。
MII_CRS:载波侦听信号,仅工作在半双工模式下,由PHY控制,当发送或接收的介质非空闲时,使能此信号。 PHY必需保证MII_CRS信号在发生冲突的整个时间段内都保持有效,不需要此信号与发送/接收的时钟同步。
MII_COL:冲突检测信号,仅工作在半双工模式下,由PHY控制,当检测到介质发生冲突时,使能此信号,并且在整个冲突的持续时间内,保持此信号有效。此信号不需要和发送/接收的时钟同步。
MII_RXD[3:0]:接收数据线,每次接收4位数据,数据在MII_RX_DV信号有效时有效。MII_RXD[0]是数据的最低位,MII_RXD[3]是最高位。当MII_RX_EN无效,而MII_RX_ER有效时,MII_RXD[3:0]数据值代表特定的信息(请参考表194)。
MII_RX_DV:接收数据使能信号,由PHY控制,当PHY准备好数据供MAC接收时,使能该信号。此信号必需和帧数据的首位同步出现,并保持有效直到数据传输完成。在传送最后4位数据后的第一个时钟之前,此信号必需变为无效状态。为了正确的接收一个帧,有效电平不能滞后于数据线上的SFD位出现。
MII_RX_ER:接收出错信号,保持一个或多个时钟周期(MII_RX_CLK)的有效状态,表明MAC在接收过程中检测到错误。具体错误原因需配合MII_RX_DV的状态及MII_RXD[3:0]的数据值。
3.精简的独立于介质的接口(RMII)
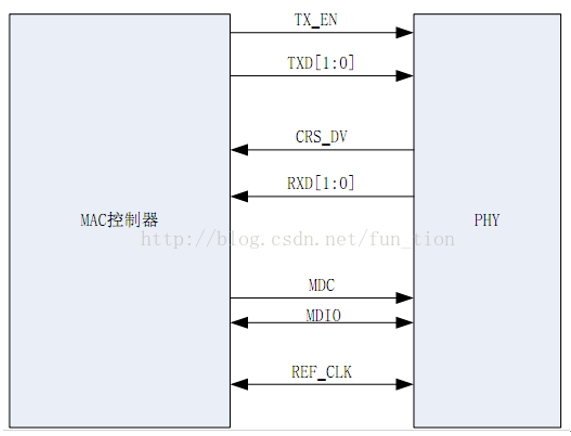
精简的独立于介质接口(RMII)规范减少了以太网通信所需要的引脚数。根据IEEE802.3标准,MII接口需要16个数据和控制信号引脚,而RMII标准则将引脚数减少到了7个。RMII具有以下特性:
时钟信号需要提高到50MHz。
MAC和外部的以太网PHY需要使用同样的时钟源
使用2位宽度的数据收发
RMII的信号线如下图所示:
如上内容转自:https://blog.csdn.net/fun_tion/article/details/70270632
1.3 Mdio总线没有找到phy_device
接下来回归到软件层面,那以太网的通信收发数据包就是使用MDC/MDIO这样的硬件接口
软件的接口是:mdiobus_read与mdiobus_write
/**

 * mdiobus_read - Convenience function for reading a given MII mgmt register

 * @bus: the mii_bus struct

 * @addr: the phy address

 * @regnum: register number to read

 *

 * NOTE: MUST NOT be called from interrupt context,

 * because the bus read/write functions may wait for an interrupt

 * to conclude the operation.

 */

int mdiobus_read(struct mii_bus *bus, int addr, u32 regnum)

{

	int retval;


	BUG_ON(in_interrupt());


	mutex_lock(&bus->mdio_lock);

	retval = bus->read(bus, addr, regnum);

	mutex_unlock(&bus->mdio_lock);


	return retval;

}

EXPORT_SYMBOL(mdiobus_read);
/**
* mdiobus_write - Convenience function for writing a given MII mgmt register
* @bus: the mii_bus struct
* @addr: the phy address
* @regnum: register number to write
* @val: value to write to @regnum
*
* NOTE: MUST NOT be called from interrupt context,
* because the bus read/write functions may wait for an interrupt
* to conclude the operation.
*/
int mdiobus_write(struct mii_bus *bus, int addr, u32 regnum, u16 val)
{
int err;
BUG_ON(in_interrupt());
mutex_lock(&bus->mdio_lock);
err = bus->write(bus, addr, regnum, val);
mutex_unlock(&bus->mdio_lock);
return err;
}
EXPORT_SYMBOL(mdiobus_write);/**
* mdio_bus_match - determine if given PHY driver supports the given PHY device
* @dev: target PHY device
* @drv: given PHY driver
*
* Description: Given a PHY device, and a PHY driver, return 1 if
* the driver supports the device. Otherwise, return 0.
*/
static int mdio_bus_match(struct device *dev, struct device_driver *drv)
{
struct phy_device *phydev = to_phy_device(dev);
struct phy_driver *phydrv = to_phy_driver(drv);
if (of_driver_match_device(dev, drv))
return 1;
if (phydrv->match_phy_device)
return phydrv->match_phy_device(phydev);
return (phydrv->phy_id & phydrv->phy_id_mask) ==
(phydev->phy_id & phydrv->phy_id_mask);
}那这块最终的read / write的实现函数在哪里呢?去以太网控制器drvier里看就好了fec_main.c中:
fec_enet_mii_init==>


        fep->mii_bus->name = "fec_enet_mii_bus";

	fep->mii_bus->read = fec_enet_mdio_read;

	fep->mii_bus->write = fec_enet_mdio_write;

	snprintf(fep->mii_bus->id, MII_BUS_ID_SIZE, "%s-%x",

		pdev->name, fep->dev_id + 1);

	fep->mii_bus->priv = fep;

	fep->mii_bus->parent = &pdev->dev;
static int fec_enet_mdio_read(struct mii_bus *bus, int mii_id, int regnum)
{
struct fec_enet_private *fep = bus->priv;
unsigned long time_left;
fep->mii_timeout = 0;
init_completion(&fep->mdio_done);
/* start a read op */
writel(FEC_MMFR_ST | FEC_MMFR_OP_READ |
FEC_MMFR_PA(mii_id) | FEC_MMFR_RA(regnum) |
FEC_MMFR_TA, fep->hwp + FEC_MII_DATA);
/* wait for end of transfer */
time_left = wait_for_completion_timeout(&fep->mdio_done,
usecs_to_jiffies(FEC_MII_TIMEOUT));
if (time_left == 0) {
fep->mii_timeout = 1;
netdev_err(fep->netdev, "MDIO read timeout\n");
return -ETIMEDOUT;
}
/* return value */
return FEC_MMFR_DATA(readl(fep->hwp + FEC_MII_DATA));
}static int fec_enet_mdio_write(struct mii_bus *bus, int mii_id, int regnum,
u16 value)
{
struct fec_enet_private *fep = bus->priv;
unsigned long time_left;
fep->mii_timeout = 0;
init_completion(&fep->mdio_done);
/* start a write op */
writel(FEC_MMFR_ST | FEC_MMFR_OP_WRITE |
FEC_MMFR_PA(mii_id) | FEC_MMFR_RA(regnum) |
FEC_MMFR_TA | FEC_MMFR_DATA(value),
fep->hwp + FEC_MII_DATA);
/* wait for end of transfer */
time_left = wait_for_completion_timeout(&fep->mdio_done,
usecs_to_jiffies(FEC_MII_TIMEOUT));
if (time_left == 0) {
fep->mii_timeout = 1;
netdev_err(fep->netdev, "MDIO write timeout\n");
return -ETIMEDOUT;
}
return 0;
}/*
* The Bus class for PHYs. Devices which provide access to
* PHYs should register using this structure
*/
struct mii_bus {
const char *name;
char id[MII_BUS_ID_SIZE];
void *priv;
int (*read)(struct mii_bus *bus, int phy_id, int regnum);
int (*write)(struct mii_bus *bus, int phy_id, int regnum, u16 val);
int (*reset)(struct mii_bus *bus);
/*
* A lock to ensure that only one thing can read/write
* the MDIO bus at a time
*/
struct mutex mdio_lock;
struct device *parent;
enum {
MDIOBUS_ALLOCATED = 1,
MDIOBUS_REGISTERED,
MDIOBUS_UNREGISTERED,
MDIOBUS_RELEASED,
} state;
struct device dev;
/* list of all PHYs on bus */
struct phy_device *phy_map[PHY_MAX_ADDR];
/* PHY addresses to be ignored when probing */
u32 phy_mask;
/*
* Pointer to an array of interrupts, each PHY's
* interrupt at the index matching its address
*/
int *irq;
};
#define to_mii_bus(d) container_of(d, struct mii_bus, dev)回归到刚刚的-19错误最终发现是phy_device为NULL了,也就是在mdio bus上没有找到对应的phy_device,那么从这里我们可以猜想注册的时候是否根本就没注册进去呢?或者是注册成功了后,在某个阶段phy_device消失了?带着这个疑问我们就要看下以太网控制器加载的流程了。
2. 网址分享
http://stackoverflow.com/questions/5308090/set-ip-address-using-siocsifaddr-ioctl
https://lkml.org/lkml/2017/2/3/396
linux PHY驱动
http://www.latelee.org/programming-under-linux/linux-phy-driver.html
Linux PHY几个状态的跟踪
http://www.latelee.org/programming-under-linux/linux-phy-state.html
第十六章PHY -基于Linux3.10
继续讨论
新讨论请用 GitHub 账号在下方发言——评论会保存在本仓库的 Discussions 里,与站点同寿; 再下方的「历史评论」是原站的只读存档。
评论(1 条,只读存档)
以下为原站的历史评论(只读存档);继续讨论请用上方的评论区。
16